Instruction Manual / Betriebsanleitung Digital Positioning Controller with integral MPU Digitale Positioniersteuerung mit integrierter MPU - BGE ...
←
→
Transkription von Seiteninhalten
Wenn Ihr Browser die Seite nicht korrekt rendert, bitte, lesen Sie den Inhalt der Seite unten
Instruction Manual / Betriebsanleitung
 Digital Positioning Controller with integral MPU
Digitale Positioniersteuerung mit integrierter MPU
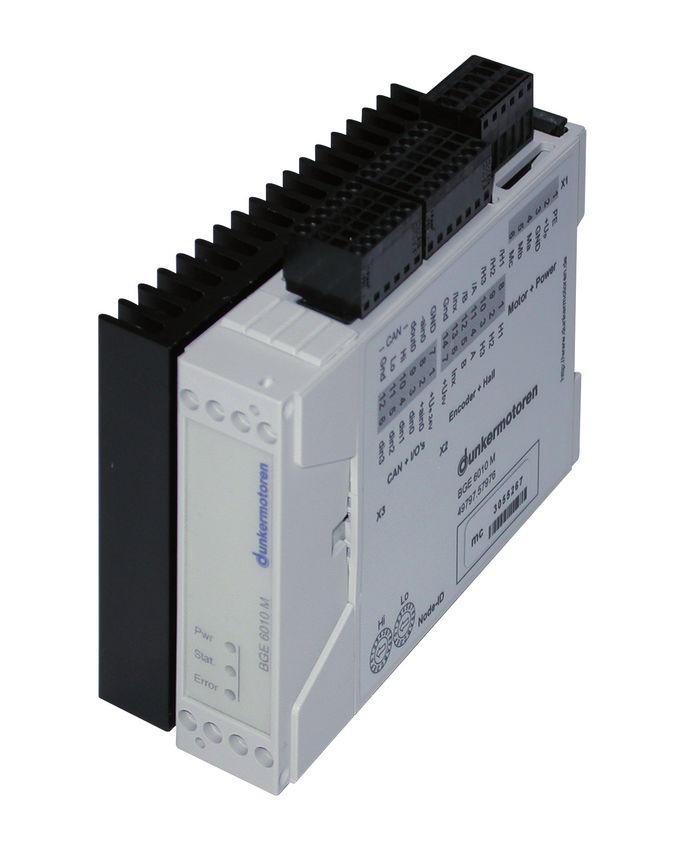
                 BGE 3515 / 6010

                 Edition / Ausgabe (05/2009)
1 Content 1 Content
1 Inhalt 1 Inhalt
Page Seite
12.5 Inputs for Encoders 25 12.5 Eingänge für Encoder 25
1 Content 2 1 Inhalt 2 12.6 Auxiliary power supplies 25 12.6 Hilfsspannungen 25
2 About this document 5 2 Über dieses Dokument 5 13 Installation 26 13 Installation 26
3 Brief description 6 3 Kurzbeschreibung 6 14 Commissioning 28 14 Inbetriebnahme 28
3.1 BGE 3515 / 6010 6 3.1 BGE 3515 / 6010 6
3.2 Explanations of terms used 7 3.2 Begriffserklärungen 7 15 Stand-alone operation, software 15 Stand-alone Betrieb, Software
3.3 Proper use 9 3.3 Bestimmungsmäßige Verwendung 9
Drive Assistant 29 Drive Assistant 29
15.1 Hardware controller 29 15.1 Hardware Regler 29
4 Safety instructions 10 4 Sicherheitshinweise 10 15.2 StarterKit 29 15.2 StarterKit 29
15.3 Introduction30 15.3 Einführung30
5 Types of operation 11 5 Betriebsarten 11 15.4 System Requirements30 15.4 Systemvoraussetzungen30
5.1 Operatin modes 11 5.1 Betriebsmodi 11 15.5 Installation of the Software Drive 15.5 Installation der Software Drive
Assistant30 Assistant30
6 General performance data 13 6 Allgemeine Leistungsdaten 13 15.6 Description of the Main Window31 15.6 Beschreibung des Hauptfensters31
15.6.1 Description of the General 15.6.1 Beschreibung der allgemeinen
Parameter Groups - Main Window31 Parametergruppen - Hauptfenster31
7 General features 14 7 Allgemeine Eigenschaften 14 15.6.2 Description of the Menu Bar 15.6.2 Beschreibung der Menüleiste
- Main Window31 - Hauptfenster31
8 Dimension 14 8 Abmessung 14 15.7 Description of the Project Window32 15.7 Beschreibung des Projektfensters32
15.7.1 Description of the General Paramter 15.7.1 Beschreibung der allgemeinen
9 Terminal assignment 15 9 Anschlussbelegung 15 Groups - Project Window33 Parametergruppen - Projektfenster33
9.1 Power supply and motor 9.1 Versorgungsspannung und 15.7.2 Description of the file cards 35 15.7.2 Beschreibung der Karteikarten 35
15.7.3 Description of the Menu Bar 15.7.3 Beschreibung der Menüleiste
connections Motoranschluss bürstenlose
- Project Window38 - Projektfenster38
BLDC 16 DC-Motoren 16
15.8 Description of the Operating Modes39 15.8 Beschreibung der Betriebsarten39
9.2 Power supply and motor 9.2 Versorgungsspannung und
15.8.1 „Standard“ Positioning Mode39 15.8.1 Positioniermodus „Standard“39
connections Motoranschluss bürstenbehaftete 15.8.2 „Complete Positioning Command“ 15.8.2 Positioniermodus
PMDC 16 DC-Motoren 16 Positioning Mode 45 „Complete Positioning Command“ 45
9.3 Hall Sensors/ Encoders 17 9.3 Hallsensor/ Encoder 17 15.8.3 „Stepper“ Positioning Mode 52 15.8.3 Positioniermodus „Stepper“ 52
9.4 Analog and digital inputs and 9.4 Analoge und Digitale Ein- und 15.8.4 „Left-Right“ Positioning Mode 58 15.8.4 Positioniermodus „Left-Right“ 58
outputs; CAN 18 Ausgänge; CAN 18 15.8.5 „Modulo“ Positioning Mode 64 15.8.5 Positioniermodus „Modulo“ 64
15.8.6 „Positioning by Event“ 15.8.6 Positioniermodus
Positioning Mode 72 „Positioning by Event“ 72
10 Connection schematic 19 10 Anschlussschema 19
15.8.7 „Velocity Standard“ 15.8.7 Geschwindigkeitsmodus
10.1 Connection brushless motor 19 10.1 Anschluss bürstenloser Motor 19
Velocity Mode 77 „Velocity Standard“ 77
10.2 Connection brush-type motor 19 10.2 Anschluss bürstenbehafteter Motor 19 15.8.8 „Velocity Multi“ 15.8.8 Geschwindigkeitsmodus
10.3 Connection Hall sensors 20 10.3 Anschluss Hallsensoren 20 Velocity Mode 80 „Velocity Multi“ 80
10.4 Connection encoder 20 10.4 Anschluss Encoder 20 15.8.9 „Current Standard“ 15.8.9 Drehmomentmodus
10.5 Connection power supply 10.5 Anschluss Spannungsversorgung Torque Mode 84 „Current Standard“ 84
motor 21 Motor 21 15.8.10 Drehmomentmodus 15.8.10 „Current Multi“
10.6 Connection power supply 10.6 Anschluss Spannungsversorgung „Current Multi“ 87 Torque Mode 87
controller 21 Regler 21
10.7 Connection CAN interface 22 10.7 Anschluss CAN-Schnittstelle 22 16 Slave in CANopen network, 16 Slave in CANopen Netzwerk,
software „mPLC“ 91 Software „mPLC“ 91
11 Block diagram 23 11 Blockschaltbild 23 16.1 Hardware controller 91 16.1 Hardware Regler 91
16.2 Motion Starter Kit 95 16.2 Motion Starter Kit 95
12 Technical Data 23 12 Technische Daten 23 16.3 Requirements 96 16.3 Vorraussetzungen 96
12.1 Digital inputs 23 12.1 Digitale Eingänge 23 16.4 Introduction 96 16.4 Einführung 96
12.2 Digital output 24 12.2 Digitale Ausgänge 24 16.5 Samples 96 16.5 Samples 96
12.3 Analog inputs 24 12.3 Analoge Eingänge 24 16.6 Documentations 97 16.6 Documentations 97
12.4 Inputs for hall sensors 24 12.4 Eingänge für Hallsensoren 24 16.7 Control software mPLC 98 16.7 Steuerungssoftware mPLC 98
Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany1 Content 2 About this document
1 Inhalt 2 Über dieses Dokument
16.7.1 Introduction 98 16.7.1 Einführung 98 2 About this document 2 Über dieses Dokument
16.7.2 System requirements 98 16.7.2 Systemvoruassetzungen 98
16.7.3 Installation of the Software mPLC 98 16.7.3 Installation der Software mPLC 98 These operating instructions introduce you to the Po- Die vorliegende Betriebsanleitung stellt Ihnen die Po-
16.7.4 Installation CAN-USB adapter 98 16.7.4 Installation CAN-USB Adapter 98 sitioning Controller BGE 3515 / 6010 and inform you sitioniersteuerung BGE 3515 / 6010 vor und informiert
16.7.5 mPLC Control Center 99 16.7.5 mPLC Control Center 99 about all necessary steps for installation and carry-ing Sie über alle Schritte zur Installation und zur Durch-
16.7.6 Python Script 100 16.7.6 Python Script 100 out initial functional tests. Further information about führung erster Funktionstests. Weitere Informationen
16.7.7 CAN monitor 103 16.7.7 CAN-Monitor 103 field bus operation is provided by the parameterisation zum Feldbusbetrieb erhalten Sie aus der Parametrier-
16.7.8 Terminal 105 16.7.8 Terminal 105 list, and from the various publications of the CIA (Can liste und diversen Unterlagen der CIA (Can in Automa-
16.7.9 Configuration 106 16.7.9 Konfiguration 106 in Automation Organisation) available at: tion Organisation): www.can-cia.de.
16.8 Objects 108 16.8 Objekte 108 www.can-cia.de.
16.8.1 Object- / SDO-variable 108 16.8.1 Objekt- / SDO-Variable 108
16.8.2 Setup CAN objects 110 16.8.2 Anlegen von CAN-Objekte 110
16.8.3 Setup CAN variables 111 16.8.3 Anlegen von CAN-Variablen 111
16.8.4 Transmit / Receive 113 16.8.4 Senden, Empfangen 113
16.8.5 Recording 113 16.8.5 Aufzeichnen 113 Warning! Warnhinweise!
16.9 CAN master of other manufacturer 116 16.9 CAN-Master anderer Hersteller 116 Read these Lesen und befolgen
16.10 Communication settings 117 16.10 Kommunikationseinstellungen 117 instructions carefully Sie diese sorgfältig!
16.10.1 Standard variant – LMT services117 16.10.1 Standardvariante - LMT Dienste 117 and follow them!
16.10.2 Manufacturer-specific variant 118 16.10.2 Herstellerspezifische Variante 118
16.11 Test programs and other 16.11 Testprogramme und weitere Warnings are there to protect you from danger, and to Warnhinweise sollen Sie vor Gefahr schützen oder
assistance 120 Hilfsmittel 120 help you to avoid damage to the device. helfen Ihnen, eine Beschädigung des Gerätes zu ver-
meiden.
17 Maintenance & Service 121 17 Wartung & Service 121
17.1 Maintenance, decommisioning 17.1 Wartung, Ausserbetriebsetzung
and disposal 121 und Entsorgung 121
17.2 Service & support 121 17.2 Service & Support 121 Warning! Achtung!
17.3 Scope of supply and accessories 122 17.3 Lieferumfang und Zubehör 122 Danger of Lebensgefahr durch
17.4 Download PDF-Data 122 17.4 Download PDF-Daten 122 electrocution! Stromschlag!
When you see this sign, always check that the unit is Wenn Sie dieses Zeichen sehen, dann prüfen Sie
disconnected from the electrical power supply, and stets ob das Gerät spannungsfrei und gegen ver-
take precautions to prevent unintentional switching sehentliches Einschaflten gesichert ist.
on.
Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany3 Brief description 3 Brief description
3 Kurzbeschreibung 3 Kurzbeschreibung
3 Brief description 3 Kurzbeschreibung 3.2 Explanations of terms used 3.2 Begriffserklärungen
3.1 BGE 3515 / 6010 3.1 BGE 3515 / 6010
Speed of transmission or Übertragungs-/ Kommunikati-
The electronic controllers BGE 3515 / 6010 are 4-qua- Bei der Steuerungselektronik BGE 3515 / 6010 handelt Baud rate Baud rate
communication onsgeschwindigkeit
drant positioning controllers with integral output stage es sich um eine 4-Quadranten-Positioniersteuerung
and an interface for stand-alone operation controlled mit integrierter Endstufe und Schnittstellen für den Component for the transfor- Bauteil zur Umwandlung von
Brückengleichrich-
by digital / analog inputs / outputs or for operation as Stand-alone Betrieb gesteuert über digitale oder Bridge rectifier mation from AC voltage to DC Wechselspannung in Gleich-
ter
Slave in CANopen networks (CANopen Drives Profile analoge Ein- oder Ausgänge oder für den Betrieb als voltage spannung
DSP 402, Protocol DS 301). Slave in CANopen Netzwerken (CANopen Drives Profil A communication network Kommunikationsnetzwerk bei
DSP 402, Protokoll DS 301). in which all nodes can be dem alle Knoten über passive
Bus reached via passive links, and Bus Links erreicht werden können
These electronic controllers are suitable for use with Die Steuerungselektronik ist zur Ansteurung bürsten- communication is possible in und Kommunikation in beide
brushless or conventional DC motors (e.g. our BG and loser oder bürstenbehafteter DC-Motoren (z.B. unsere both directions Richtungen möglich ist
GR/G ranges). They incorporate protection against Baureihen BG und GR/G) geeignet. Sie verfügt über
over-voltage, low voltage and excessive temperature, Überspannungs-, Unterspannungs- und Übertempe- CAN master “Command centre” of a bus CAN Master “Kommandozentrale” im Bus
and have a status indicator which shows „Ready“, raturabschaltung sowie eine Statusanzeige „Ready“, Gateway for the conversion Gateway zur Umsetzung von
„Status“ or „Error“. The most important parameters „Status“ und „Error“. Die wesentlichen Parameter kön- CAN adapter CAN-Adapter
of TCP/IP to CANopen TCP/IP in CANopen
can be changed „on the fly“ via the CAN interface. nen über die Schnittstelle auch „in fly“ verändert wer-
den. Graphic interface for the sup- Graphische Oberfläche zur Un-
CAN monitor port of commissioning the CAN-Monitor terstützung der Inbetriebnahme
Information about the rotor position can be supplied Informationen zur Motorlage können der Positionier- drive des Antriebs
to the positioning controller either by the voltage or by steuerung bei bürstenbehafteten Motoren über die
Graphic interface for commis- Grafische Oberfläche zur Inbe-
an encoder in the case of commutator motors, or, for Spannung oder per Encoder zugeführt werden, bei Drive Assistant Drive Assistant
sioning and parameterisation triebnahme und Parametrierung
brushless motors, by Hall sensors or an incremental bürstenlosen Motoren per Hallsensoren oder per In-
encoder. krementalgeber (Encoder). A group of profiles for net- Eine Gruppe von Profilen für
works in the following fields Netzwerke in folgenden Anwen-
of application: industrial au- dungen: IndustrielleAutomation,
CANopen CANopen
tomation, medical equipment, Medizintechnik, Gehäuseau-
building automation, railway tomation, Schienenfahrzeuge,
vehicles, ships, trucks, … Seefahrt, Trucks, …
Default settings Preset values Defaultwerte Voreingestellte Werte
CANopen device profile for CANopen Geräteprofil An-
DSP 402 DSP 402
drives and controllers triebe und Regler
Smoothing capa- Component to smooth the Glättungskonden- Bauteil zur Glättung von
citor fluctuation voltage sator Spannungsschwankungen
Sensors for determining the Sensor zur Positionsbestim-
Hall sensors Hallsensoren
position of a rotor mung des Rotors
Reverenzierverfahren zur in-
Reference procedure for the
itialen Bestimmung der Po-
Homing initial regulation of the drive Homing
sition des Antriebs in einem
position in the system
System
Signals given form the enco- Signale erzeugt von dem im
Impulse flanks Impulsflanken
der in the drive Antrieb integrierten Geber
Programming- / Parametri- Programmier- / Parametrier-
In fly zation possibility in attached In fly möglichkeit im eingebauten
condition Zustand
Reference mark of the inte- Referenzmarke der inte-
Index impulse Indeximpuls
grated encoder panel grierten Geberscheibe
Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany3 Brief description 3 Brief description
3 Kurzbeschreibung 3 Kurzbeschreibung
Digitaler Lagegeber. Eine in- 3.3 Proper use 3.3 Bestimmungsmäßige Verwendung
Digital position indicator. An in- terne Logik erzeugt aus dem
ternal logic processes a signal Signal von Fotodioden zwei - The positioning controller is a vendor part and - Die Positioniersteuerung ist ein Zulieferteil und
Incremental Inkrementalgeber
from photodiodes to produce um 90° verschobene Recht- may be used in the configuration described in darf in der beschriebenen Konfiguration in
encoder
two square-wave signals with ecksignale. machines and plant (industrial sector). Maschinen und Anlagen eingesetzt werden
a phase difference of 90°. - The positioning controller must be securely mounted (industrieller Bereich).
and must only be used with the cables and - Die Positioniersteuerung muss fest montiert werden
The motor voltage is distribu- Die Motorspannung wird accessories specified by Dunkermotoren. und darf nur mit den von Dunkermotoren
Commutation ted in blocks by an electronic Kommutierung durch eine Elektronik block- - The positioning controller may only be put into spezifizierten Kabeln und Zubehörteilen eingesetzt
controller weise weitergeschaltet service after the complete system has been installed werden.
in conformity with EMC requirements. - Die Positioniersteuerung darf erst nach
Motion controller Motor control Motion controller Motorsteuerung
EMV-gerechter Montage des Gesamtsystems in
Interface for commissioning Oberfläche zur Inbetriebnah- Betrieb genommen werden.
mPLC and for controlling CANopen mPLC me und zur Steuerung von
slaves CANopen Slaves
Gerätenummer/ -adresse, die
Device number/address – jedem Gerät in einem Bus-
Node ID must be assigned to every Node-ID
system zugeordnet werden
device in a bus system muss
Programming language used Programmiersprache der
Phyton script in the Dunkermotoren Motion Phyton Skript Dunkermotoren Motion Star-
Starter Kit software ter Kit Software
Position mode Regulation of position Position Mode Lageregelung
Einstellungen zum Beschleu-
Settings to accelerate and Rampen nigen und Bremsen des An-
Ramps
brake the drive triebs
Fast speed regulation as a Schnelle Drehzahlregelung
subordinate speed controller als untergelagerter Drehzahl-
SVEL Mode for a higher-level positioning SVEL Mode regler für übergeordnete Po-
system sitioniersysteme
(e.g. a CNC-control system). (z.B. CNC-Steuerungen).
Abschlußwiderstand, der
Terminal resistance, which is nach dem letzten Teilnehmer
to be used after the last par- Terminator innerhalb des Kommunikati-
Terminator
ticipant in the communication onsnetzwerks zu verwenden
network ist
Torque regulation, also referred Auch “Current Mode”, Dreh-
Torque mode Torque Mode
to as “Current Mode” momentregelung
Trajectory Sequence of motions Trajektorie Bewegungsablauf
Component for the branching Bauteil zur Verzweigung des
T-connector in the communication net- T-Stück
Kommunikationsnetzwerks
work
Velocity mode Speed regulation Velocity Mode Drehzahlregelung
Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany4 Safety instructions 5 Types of operation
4 Sicherheitshinweise 5 Betriebsarten
4 Safety instructions 4 Sicherheitshinweise 5 Types of operation 5 Betriebsarten
With the controller BGE 3515 / 6010, 2 different types Mit der Steuerung BGE 3515 / 6010 können 2 verschie-
Warning! Achtung! of operation can be operated. dene Betriebsarten in Betrieb genommen werden.
Before commissioning, Vor der Inbetriebnah-
the following safety in- me sind unbedingt die The stand-alone operation offers the possibility to Der Stand-alone Betrieb ermöglicht das parametrie-
structions must, without nachfolgen Sicher- parameterize the motors over the external controller ren von Motoren über den externen Regler via der
fail, be read, understood heitshinweise zu lesen via the software „Drive Assistant“, which is contained Software „Drive Assistant“, die im „StarterKit“ enthal-
and observed! Failure und zu beachten! Eine in the „StarterKit“ (for details, see „Commissioning“). ten ist (näheres dazu, siehe „Inbetriebnahme“).
to follow them can result Nichtbeachtung kann zu
in danger to persons or Gefahren bei Personen The slave in CANopen network offers the Der Slave in CANopen Netzwerk ermöglicht das an-
damage to the machine. oder Beschädigungen possibility to control the motors over the external steuern von Motoren über den externen Regler via der
an der Maschine führen! controller via the software „mPLC“, which is contained Software „mPLC“, die im „Motion Starter Kit“ enthalten
in the „Motion Starter Kit“ (for details, see „Commis- ist (näheres dazu, siehe „Inbetriebnahme“).
To ensure trouble-free operation, appropriate methods Der störungsfreie Betrieb setzt entsprechenden Trans- sioning“).
of transport and conditions of storage must be employed. port und Lagerung nach den entsprechenden Vorga-
Please store the module so that it is protected from dust, ben voraus: Lagern Sie bitte das Modul geschützt vor 5.1 Operatin modes 5.1 Betriebsmodi
dirt, and moisture. Take care that storage conditions are Staub, Schmutz und Feuchtigkeit. Achten Sie darauf,
within the specified limits for storage temperature and dass die Lagerungsbedingungen nicht außerhalb der Both types of operation provides different operation Beide Betriebsarten unterstützen verschiedene Me-
humidity. Please transport the module under storage Lagerungstemperatur bzw. Luftfeuchtigkeit liegt. Trans- modes to configure the motor exactly: triebsmodi, mit denen der Motor genau konfiguriert
conditions with additional protection against shocks portieren Sie die Module bitte unter Lagerungsbedin- werden kann:
and jolts. gungen, zusätzlich noch stoßgeschützt.
SVEL mode SVEL Mode
Follow the instructions for installation and adjustment Befolgen Sie die Anleitung für den Aufbau und die Ein-
precisely. Installation and dismounting must only richtung genau. Die Montage/Demontage darf nur im
Fast speed regulation as a subordinate speed control- Schnelle Drehzahlregelung als untergelagerter Dreh-
be carried out with the unit disconnected from the spannungslosen Zustand erfolgen. Die Module dür-
ler for a higher-level positioning system (e.g. a CNC- zahlregler für übergeordnete Positioniersysteme (z.B.
electrical power supply. The module must only be fen nur von qualifiziertem Personal nach den entspre-
control system). CNC-Steuerungen).
installed and adjusted by qualified persons in accor- chenden Normen eingebaut und eingerichtet werden.
dance with the relevant standards. Qualified persons Als qualifiziert gilt eine Person dann,
are those who: • wenn sie aufgrund ihrer Erfahrung mögliche Positioning mode using Hall sensors Position Mode per Hallsensoren
• on the basis of their experience, can recognise and Gefahren erkennen und vermeiden kann,
avoid potential dangers; • wenn ihr die Unfallverhütungsvorschriften für die ein Three Hall sensors spaced at 120° (included in all BG Drei um 120° versetzte Hallsensoren (Bestandteil aller
• are familiar with the accident-prevention regulations gesetzten Geräte bekannt sind drives) provide information about rotation of the motor. BG-Antriebe) geben Aufschluss über die Weiterbewe-
for the equipment employed; und When very precise positioning is required, an encoder gung des Motors. Bei sehr hohen Anforderungen an
and • wenn sie gemäß den Normen Stromkreise und Ge with higher resolution should be employed. die Positioniergenauigkeit sollte ein Encoder mit hoher
• are able to connect circuits and install equipment in räte in Betrieb setzen und installieren darf. Auflösung verwendet werden.
accordance with the standards and regulations.
Positioning mode using an encoder Position Mode per Encoder
Please observe any regional standards and regulations Bitte beachten Sie die regionalen Normen im Einsatz-
that apply in the area where the components are used. gebiet der Komponenten. Beachten Sie bitte auch By selecting a drive with an encoder with higher resolu- Durch den Einsatz eines Antriebs mit Encoder mit ei-
Please also observe the safety instructions that apply die Sicherheitshinweise der zu steuernden Geräte tion, a control circuit can be set up which permits very ner hohen Auflösung wird ein Regelkreis aufgebaut der
to the equipment or machinery that is to be controlled. und Maschinen. Um Gefahren abwenden zu können, precise positioning. eine exakte Positionierung ermöglicht.
So as to be able to avert hazards, make sure that there vergewissern Sie sich, dass ein funktionstüchtiger
is an EMERGENCY-STOP switch in immediate reach NOTAUS-Schalter in direkter Reichweite mit unbehin- Torque mode Torque Mode
and with unrestricted access. dertem Zugang liegt.
The current draw of the motor (which is proportional to Die Stromaufnahme des Motors (entspricht dem Dreh-
the torque) is monitored and adjusted according to the moment) wird überwacht und entsprechend der Vorga-
setting. be eingestellt.
10 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 11
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany5 Types of operation 6 General performance data
5 Betriebsarten 6 Allgemeine Leistungsdaten
Velocity mode using Hall sensors Velocity Mode per Hallsensoren 6 General performance data 6 Allgemeine Leistungsdaten
When regulating using Hall sensors (included in all BG Bei Regelung über Hallsensoren (Bestandteil aller
Description BGE 3515 / 6010 Beschreibung BGE 3515 / 6010
drives), rotation will be irregular at low speeds. This BG-Antriebe) ist mit unsanftem Rundlauf bei kleinen
control system is used mainly in combination with mo- Drehzahlen zu rechnen. Dieses Regelungssystem wird
tors with gear reducers. It is important that the speed vor allem bei Einsatz von Getriebemotoren verwendet.
can be set in a closed, digital control loop, and that the Wichtig ist, dass die Geschwindigkeitsregelung im ge- Performance data Leistungsdaten
temperature remains stable over time. schlossenen digitalen Regelungskreislauf eingestellt Supply voltage, Versorgungsspannung
werden kann und über die Zeit und die Temperatur sta- 10 ... 30 V DC 10 ... 30 V DC
electronics Ue Elektronik Ue
bil ist.
Supply voltage, 10 ... 30 V 10 ... 60 V Versorgungsspannung 10 ... 30 V 10 ... 60 V
power Up DC DC Leistung Up DC DC
Velocity mode using an encoder Velocity Mode per Encoder
Current draw (no load Stromaufnahme (alle
By selecting a drive with an encoder with higher re- Durch den Einsatz eines Antriebs mit Encoder mit ei- typ. 40 mA @ 24 V typ. 40 mA @ 24 V
at all outputs) Ausgänge unbelastet)
solution, a control circuit can be set up which permits ner hohen Auflösung wird ein Regelkreis aufgebaut der
smooth rotation at low speeds. It is important that the sanften Rundlauf bei niedrigen Geschwindigkeiten er- Maximum output Maximaler
15 A 15 A
speed can be set in a closed, digital control loop, and laubt. Wichtig ist, dass die Geschwindigkeitsregelung current Ausgangsstrom
that the temperature remains stable over time. im geschlossenen digitalen Regelungskreislauf einge- Permissible continuous zulässiger Daueraus-
stellt werden kann und über die Zeit und die Tempera- 14 A 9A 14 A 9A
output current gangsstrom
tur stabil ist.
Voltage regulation Spannungsregelung Protective devices Schutzeinrichtungen
(Only for commutator motors) (nur bürstenbehaftete Motoren)
Over-voltage Überspannungs-
yes ja
cut-off abschaltung
The actual motor voltage (measured at the appropriate Die wirkliche Motorspannung (gemessen an den ent-
output terminals of the controller) is compared with the sprechenden Ausgangsklemmen des Controllers) wird Low-voltage Unterspannungs-
yes ja
required voltage and regulated accordingly. The motor mit der erforderlichen verglichen und entsprechend cut-off abschaltung
voltage (speed of rotation) is thus independent of vari- nachgeregelt. Dadurch ist die Motorspannung (Dreh-
ations in the supply voltage. zahl) unabhängig von Schwankungen der Versor- Over-temperature Übertemperatur-
yes ja
gungsspannung cut-off abschaltung
IxR-compensation IxR-Kompensation Inputs & outputs Ein- & Ausgänge
(Only for commutator motors) (nur bürstenbehaftete Motoren)
Digital inputs 5 Digitale Eingänge 5
A motor consists, in principle, of a resistance and a coil. Ein Motor besteht aus einem Widerstand und einer
When the motor has to produce torque the appropri- Spule. Wird am Motor ein Drehmoment abgenommen, Digital outputs 1 Digitale Ausgänge 1
ate current flows in it. The resistance causes a voltage fliesst ein entsprechender Strom durch den Motor. Analog inputs 1 (+/- 10 V) Analoge Eingänge 1 (+/- 10 V)
drop, which increases as the current rises. A lower vol- Über den Widerstand entsteht ein Spannungsabfall,
tage supply to the motor means that the speed is low- der mit steigendem Stromfluss größer wird. Eine ge-
er. With IxR-compensation, to make up for this drop in ringere Spannung am Motor bedeutet eine geringere CAN interface CAN-Schnittstelle
speed and achieve the specified speed, the voltage at Drehzahl. Um diesen Drehzahlabfall zu kompensieren
the output terminals to the motor is increased by the und die vorgegebene Drehzahl zu erreichen, wird die Baud rate Up to 1 Mbit/s Baudrate bis 1 Mbit/s
amount of the voltage drop. Spannung bei einer IxR-Kompensation an der ausge- Protocol DS301 V3.0 Protokoll DS301 V3.0
henden Motorklemme entsprechend dem Spannungs-
verlust erhöht. Device profile DSP402 V2.0 Geräteprofil DSP402 V2.0
Ambient conditions Umgebungsbedingungen
Temperature 0 ... +70 °C Temperatur 0 ... +70 °C
Humidity Feuchtigkeit
20 ... 80 % 20 ... 80 %
(non-condensing) (nicht kondensierend)
12 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 13
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany7 General features 9 Terminal assignment
7 Allgemeine Eigenschaften 9 Anschlussbelegung
7 General features 7 Allgemeine Eigenschaften 9 Terminal assignment 9 Anschlussbelegung
Warning! Achtung!
Description Data Beschreibung Wert Klemme X3.1 (Spannungs-
Terminal X3.1 (electronic sup-
ply) is internal not connected versorgung Elektronik) ist
with terminal X1.2 (power intern nicht mit Klemme X1.2
Degree of protection to Schutzart nach (Spannungsversorgung Lei-
IP20 IP20 supply) .
DIN 40050 / IEC 144 DIN 40050 / IEC 144 stung) verbunden.
CAN – CPU electrically CAN – CPU elektrisch Terminal X2.2 (Earth for po-
Yes Ja Klemme X1.3 (Masse Lei-
connected verbunden wer supply) is internal con-
nected with terminal X2.14 stung) ist intern mit Klemme
CPU - GND and I/O - GND CPU - GND und I/O - GND (Earth for Hall/encoder). X2.14 (Masse für Hall/Enco-
Yes Ja
electrically connected elektrisch verbunden der) verbunden.
Mounting Fixing clips Befestigung Bohrlöcher
Warning! Achtung!
Display Anzeige By assembling the cables Beachten Sie bei der Kon-
Ready LED Green Ready-LED Grün consider the skinning length fektionierung aller Leitungen
of the particular connectors. auf die Abisolierlänge für die
Status LED Yellow Status-LED Gelb jeweiligen Stecker.
At the double-row connectors Bei den doppelreihigen Ste-
Error LED Red Error-LED Rot
(X2,X3) it averages 7 mm at ckern (X2,X3) beträgt sie 7
the single-row connector (X1) mm, bei dem einreihigen Ste-
it average 10 mm. cker (X1) beträgt sie 10 mm.
Cable cross-section of push-in terminals Kabelquerschnitte der Steckkontakte
Motor plug Up to 1.5 mm 2
Motorstecker bis 1,5 mm2
Dual plug Up to 1 mm2 Doppelstecker bis 1 mm2
8 Dimension 8 Abmessung
14 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 15
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany9 Terminal assignment 9 Terminal assignment
9 Anschlussbelegung 9 Anschlussbelegung
9.1 Power supply and motor 9.1 Versorgungsspannung und 9.3 Hall Sensors/ Encoders 9.3 Hallsensor/ Encoder
connections BLDC Motoranschluss bürstenlose
DC-Motoren Desi- Signal Bezeich- Signal-
Terminal Description Klemme Beschreibung
gnation direction nung richtung
Designa- Signal Bezeich- Signal- X2.1 H1 Hall sensor signal 1 Input X2.1 H1 Hallsensorsignal 1 Eingang
Terminal Description Klemme Beschreibung
tion direction nung richtung
X2.2 H2 Hall sensor signal 2 Input X2.2 H2 Hallsensorsignal 2 Eingang
Protective X1.1 PE Schutzerde -
X1.1 PE - X2.3 H3 Hall sensor signal 3 Input X2.3 H3 Hallsensorsignal 3 Eingang
earth
Spannungs-
Supply X1.2 +Up versorgung Eingang Incr. encoder - Inc. Encoder -
X1.2 +Up Input X2.4 A Input X2.4 A Eingang
voltage, power Leistung track A Spur A
Earth for Masse Incr. encoder - Inc. Encoder -
X1.3 GND - X1.3 GND - X2.5 B Input X2.5 B Eingang
power supply Leistung track B Spur B
Motor Motor- Incr. encoder - Inc. Encoder -
X1.4 Ma Output X1.4 Ma Ausgang X2.6 INX Input X2.6 INX Eingang
connection A anschluss A index Index
Motor Motor- Supply voltage Spannungsversor-
X1.5 Mb Output X1.5 Mb Ausgang X2.7 +U5V for Output X2.7 +U5V gung für Ausgang
connection B anschluss B
Hall/encoder + 5V Hall/Enc + 5V
Motor Motor-
X1.6 Mc Output X1.6 Mc Ausgang Negated Hall- Negiertes
connection C anschluss C X2.8 /H1 Input X2.8 /H1 Eingang
sensor signal 1 Hallsensorsignal 1
9.2 Power supply and motor 9.2 Versorgungsspannung und X2.9 /H2
Negated Hall-
Input X2.9 /H2
Negiertes
Eingang
connections PMDC Motoranschluss bürstenbehaftete sensor signal 2 Hallsensorsignal 2
DC-Motoren Negated Hall- Negiertes
X2.10 /H3 Input X2.10 /H3 Eingang
sensor signal 3 Hallsensorsignal 3
Designa- Signal Bezeich- Signal- Incr. encoder - Inc. Encoder -
Terminal Description Klemme Beschreibung X2.11 /A Input X2.11 /A Eingang
tion direction nung richtung negated track A Negierte Spur A
Protective X1.1 PE Schutzerde - Incr. encoder - Inc. Encoder -
X1.1 PE - X2.12 /B Input X2.12 /B Eingang
earth negated track B Negierte Spur B
Spannungs-
Supply X1.2 +Up versorgung Eingang Incr. encoder - Inc. Encoder -
X1.2 +Up Input X2.13 /INX Input X2.13 /INX Eingang
voltage, power Leistung negated index Negierter Index
Earth for Masse Earth for Masse für
X1.3 GND - X1.3 GND - X2.14 GND - X2.14 GND -
power supply Leistung Hall/encoder Hall/Encoder
X1.4 Ma Motor + Output X1.4 Ma Motor + Ausgang
X1.5 Mb Motor - Output X1.5 Mb Motor - Ausgang
X1.6 Mc n.c. Output X1.6 Mc n.c. Ausgang
16 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 17
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany9 Terminal assignment 10 Connection schematic
9 Anschlussbelegung 10 Anschlussschema
9.4 Analog and digital inputs and 9.4 Analoge und Digitale Ein- und 10 Connection schematic 10 Anschlussschema
outputs; CAN Ausgänge; CAN
Warning!
Designa- Signal Bezeich- Signal- Before installation, the safety
Achtung!
Terminal Description Klemme Beschreibung Vor der Installation sind unbe-
tion direction nung richtung instructions must, without fail,
dingt die Sicherheitshinweise
be read, understood and ob-
Supply voltage, Spannungsversor- zu lesen und zu beachten!
X3.1 +Ue - X3.1 +Ue 24V - served!
24V electronics gung Elektronik Gerät spannungsfrei schal-
Disconnect the unit from the
ten!
+AIN 0 / + analog input / +AIN 0 / + analoger Eingang/ electrical power supply.
X3.2 Input X3.2 Eingang
DIN4 Digital input 4 DIN 4 digitaler Eingang 4
X3.3 DIN 0 Digital input 0 Input X3.3 DIN 0 digitaler Eingang 0 Eingang Failure to follow them can result in danger to persons Eine Nichtbeachtung kann zu Gefahren an Personen
or damage to the machine. oder Beschädigungen and der Maschine führen.
X3.4 DIN 1 Digital input 1 Input X3.4 DIN 1 digitaler Eingang 1 Eingang
X3.5 DIN 2 Digital input 2 Input X3.5 DIN 2 digitaler Eingang 2 Eingang 10.1 Connection brushless motor 10.1 Anschluss bürstenloser Motor
X3.6 DIN 3 Digital input 3 Input X3.6 DIN 3 digitaler Eingang 3 Eingang
Earth for
X3.7 GND - X3.7 GND Masse Elektronik -
electronics
X3.8 -AIN 0 - analog input Input X3.8 -AIN 0 - analoger Eingang Eingang
X3.9 DOUT 0 Digital output 0 Output X3.9 DOUT 0 digitaler Ausgang 0 Ausgang
X3.10 CAN_HI CAN high Bus X3.10 CAN_HI CAN High Bus
X3.11 CAN_LO CAN low Bus X3.11 CAN_LO CAN Low Bus
CAN_ CAN_
X3.12 CAN earth - X3.12 CAN Masse -
GND GND
10.2 Connection brush-type motor 10.2 Anschluss bürstenbehafteter Motor
18 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 19
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany10 Connection schematic 10 Connection schematic
10 Anschlussschema 10 Anschlussschema
10.3 Connection Hall sensors 10.3 Anschluss Hallsensoren 10.5 Connection power supply 10.5 Anschluss Spannungsversorgung
motor Motor
Warning! Achtung!
Only with burshless DC mo- Nur bei bürstenlosen Gleich-
tors! stromotoren!
10.6 Connection power supply 10.6 Anschluss Spannungsversorgung
controller Regler
10.4 Connection encoder 10.4 Anschluss Encoder
20 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 21
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany10 Connection schematic 11 Block diagram
10 Anschlussschema 11 Blockschaltbild
10.7 Connection CAN interface 10.7 Anschluss CAN-Schnittstelle 11 Block diagram 11 Blockschaltbild
12 Technical Data 12 Technische Daten
12.1 Digital inputs 12.1 Digitale Eingänge
Description Data Beschreibung Wert
Number of inputs 5 Anzahl 5
Input voltage, low Eingangsspannung Low
-30 V ... 5 V -30 V ... 5 V
(UIN low) (UIN low)
Input voltage, high Eingangsspannung High
15 V ... 30 V 15 V ... 30 V
(UIN high) (UIN high)
Input current, high max. Eingangsstrom High max.
typ. 5.3 mA typ. 5.3 mA
( @ UIN = 30 V ) ( @ UIN = 30 V )
Conducted emission limits CE conform Störspannungsfestigkeit CE-Konform
Maximum frequency Ca. 500 Hz Maximale Frequenz Ca. 500 Hz
22 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 23
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany12 Technical Data 12 Technical Data
12 Technische Daten 12 Technische Daten
12.2 Digital output 12.2 Digitale Ausgänge 12.5 Inputs for Encoders 12.5 Eingänge für Encoder
Description Data Beschreibung Wert
Number of inputs 3 Anzahl 3
Differential or Differentiell od.
Type Typ
single-ended Single ended
Inputs A, /A, B, /B, I, /I Eingänge A, /A, B, /B, I, /I
Input voltage 5V Eingangsspannung 5V
Max. cycle frequency 500 kHz max. Taktfrequenz 500 kHz
Conducted emission limits CE conform Störspannungsfestigkeit CE-Konform
Description Data Beschreibung Wert
Number of outputs 1 Anzahl 1
Type Positive switching Typ Plus schaltend 12.6 Auxiliary power supplies 12.6 Hilfsspannungen
Max. output current 0.5 A max. Ausgangsstrom 0.5 A
Description Data Beschreibung Wert
Short-circuit resistant Yes Kurzschlussfest Ja
Power supplies for Hall sensors and encoders Versorgungsspannung für Hallsensoren und Encoder
Potential-free No Potentialfrei Nein
Output voltage 5 V ± 5% Ausgangsspannung 5 V ± 5%
Maximum load 200 mA Maximale Belastung 200 mA
12.3 Analog inputs 12.3 Analoge Eingänge
Description Data Beschreibung Wert
Number of inputs 1 Anzahl 1
Type Differential Typ Differentiell
Measurement range ±10 V Messbereich ±10 V
Resolution 10 bit Auflösung 10 Bit
Input impedance Eingangsimpedanz
Ca. 150 kOhm ca. 150 kOhm
(differential) (differentiell)
Conducted emission limits CE conform Störspannungsfestigkeit CE-Konform
12.4 Inputs for hall sensors 12.4 Eingänge für Hallsensoren
Description Data Beschreibung Wert
Number of inputs 3 Anzahl 3
Differential or Differentiell od.
Type Typ
single-ended Single ended
H1, /H1, H2, /H2, H1, /H1, H2, /H2,
Inputs Eingänge
H3, /H3 H3, /H3
Input voltage 5V Eingangsspannung 5V
Max. cycle frequency 3 kHz max. Taktfrequenz 3 kHz
Conducted emission limits CE-Konform Störspannungsfestigkeit CE-Konform
24 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 25
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany13 Installation 13 Installation
13 Installation 13 Installation
13 Installation 13 Installation Smoothing capacitor: during braking operations, ki- Glättungskondensator: Bei Bremsvorgängen wird
netic energy is stored as electrical energy in an interme- die kinetische Energie als elektrische Energie in den
diate circuit of the regulation circuit. This can cause ex- Zwischenkreis des Regelkreises zurückgeführt. Dabei
Warning! Achtung! cessive voltage in the intermediate circuit, which, in an kann es im Zwischenkreis zu Spannungsüberhöhungen
Before installation, the safety in- extreme case, could cause damage to electrical com- kommen, die im Extremfall Schäden an elektrischen
Vor der Installation sind unbe-
structions must, without fail, be ponents. To prevent this, a DC-power supply should Bauteilen verursachen können. Um dies zu verhin-
dingt die Sicherheitshinweise zu
read, understood and observed! be used which has a bridge rectifier and a smoothing dern sollten DC-Netzteile mit Brückengleichrichter und
lesen und zu beachten! Gerät
Disconnect the unit from the capacitor of at least 1000 µF per 1 A nominal motor einem Glättungskondensator von mindestens 1000 µF
spannungsfrei schalten!
electrical power supply. current. In addition, we recommend that a discharge pro 1 A Motornennstrom verwendet werden. Zusätz-
Vorsicht! resistor (e.g. 1 kΩ, power loss > U2/1000Ω) is used. lich wird die Verwendung eines Entladewiderstands
Take care! Achten Sie bei der Installation (z. B. 1 kΩ, Verlustleistung > U2/1000Ω) empfohlen.
During installation, ensure that darauf, dass die Steckverbinder
connectors are not damaged. nicht beschädigt werden. Umge-
Bent pins can cause a short cir- Warning! Achtung!
bogene Pins können den Regler If there is frequent heavy bra- Bei häufigem starken Brem-
cuit and destroy the controller. durch Kurzschluss zerstören. king, the ballast resistor, and sen kann der Ballastwider-
in consequence other circuit stand und als Folge auch
Warning! Achtung!
components, may be over- weitere Schaltungsteile über-
Do not confuse the power supply Vertauschen Sie nicht die Span-
loaded and damaged unless lastet und zerstört werden,
lines! nungsversorgungsleitungen!
appropriate measures are falls nicht geeignete Maß-
The entire circuitry is designed for Die gesamte Schaltung ist auf
taken to prevent excessive nahmen zur Vermeidung von
a correctly-poled direct-current gepolte Gleichspannung ausge-
voltage (see „Smoothing ca- zu starken Spannungsüber-
supply. If you reverse the plus legt. Wenn Sie den Plus- und Mi-
pacitor“, above). höhungen ergriffen werden
and minus poles, the electronics nuspol vertauschen, nimmt die
(s.o. Glättungskondensator)
will be severely damaged. Elektronik schweren Schaden.
Warning! Achtung! The electrical supplies for power and logic (electronics) Die Spannungsversorgungen für Leistung und Logik
First connect only the control cir- Schliessen Sie zuerst nur die may only be switched in parallel when there is no pos- (Elektronik) dürfen nur dann parallel geschalten wer-
cuit to the power supply. Do not Steuerung an die Stromversor- sibility of voltage spikes exceeding 30 V. den, wenn Spannungsspitzen von über 30 V ausge-
connect the motor yet! Set the gung an. Schliessen Sie den schlossen werden können.
desired parameters and opera- Motor noch nicht an! Stellen Sie
ting modes, and check whether die gewünschten Parameter und When connecting, please remember that there is no re- Beachten Sie beim Anschließen, dass für die Versor-
the LEDs indicate normal ope- Arbeitsmodi ein und überprüfen verse-pole protection for the supply voltage. All outputs gungsspannungen kein Verpolungsschutz besteht.
ration. Only connect the motor Sie, ob die LEDs einen norma- have short-circuit protection. Sämtliche Ausgänge sind kurzschlusssicher ausge-
when that is the case. len Betrieb anzeigen. Erst dann führt.
darf der Motor angeschlossen
werden.
26 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 27
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany14 Commissioning 15 Stand-alone operation
14 Inbetriebnahme 15 Stand-alone Betrieb
14 Commissioning 14 Inbetriebnahme 15 Stand-alone operation, software 15 Stand-alone Betrieb, Software
Drive Assistant Drive Assistant
When the power supply has been connected, the unit Ist die Spannungsversorgung hergestellt kann das Ge-
can be switched on. The module is then open to access rät eingeschaltet werden. Nun kann der softwareseitige
from the software side. Zugriff auf das Modul erfolgen. 15.1 Hardware controller 15.1 Hardware Regler
For the connection between the Positioning Controller Für die Verbindung zwischen Positioniersteuerung und
and a PC, you need the appropriate Starter Kit with PC benötigen Sie das passende StarterKit mit Adapter- Examine with connecting the conntroller that the de- Prüfen Sie bei anschließen des Reglers ob die Co-
adapter cable and software. kabel und Software. code switches at the controller are correctly adjusted! dierschalter am Regler richtig eingestellt sind!
The stand-alone operation requires the „Starter Kit“ Der Stand-alone Betrieb benötigt das „Starter Kit“ mit Dunkermotoren allege the following delivery status: Dunkermotoren gibt folgenden Auslieferungszustand vor:
with the software „Drive Assistant“. der Software „Drive Assistant“.
(not included in the scope of supply of the positioning (Nicht im Lieferumfang der Positioniersteuerung ent- Decode switch CAN_HI: 7 Codierschalter CAN_HI: 7
controller) halten) Decode switch CAN_LO: F Codierschalter CAN_LO: F
The slave in CANopen network requires the „Motion Das Slave in CANopen Netzwerk benötigt das „Moti-
Starter Kit“ with the software „mPLC“. on Starter Kit“ mit der Software „mPLC“. Thus its ensured that the controller can be identified Somit ist gewährleistet, dass der Regler von der Soft-
(not included in the scope of supply of the positioning (Nicht im Lieferumfang der Positioniersteuerung ent- from the software „Drive Assistant“. ware „Drive Assistant“ erkannt wird.
controller) halten)
Further inforamtion you can find under chapter 15 Weitere Informationen finden Sie unter Kapitel 15 The address cannot be changed within the software! Die Adresse kann innerhalb der Software nicht geän-
respectively 16. bzw. 16. dert werden!
If the controller should be parameterized in the Soll der Regler im Stand-alone Betrieb parametriert
stand-alone operation, continue with chapter 15. werden, fahren Sie mit Kapitel 15 fort.
If the controller should be conntected to a CANo- Soll der Regler an ein CANopen Netzwerk (Slave in
pen network (slave in CANopen), continue with CANopen) angeschlossen werden, fahren Sie mit
chapter 16. Kapitel 16 fort.
15.2 StarterKit 15.2 StarterKit
To use the software „Drive Assistant“, the user have to Um die Software „Drive Assistant“ nutzen zu können,
order the StarterKit for the stand-alone operation se- muss der Anwender das StarterKit für den Stand-alone
parately. Betrieb seperat bestellen.
The StarterKit contains: Im StartkerKit enthalten sind:
- USB adapter with connecting cable - USB-Adapter mit Verbindungskabel
- Connection adapter (from Controller to connecting - Anschlussadapter (von Regler zu Verbindugskabel)
cable)
- the software „Drive Assistant“ - die Software „Drive Assistant“
SNR StarterKit: 27573 35617 SNR StarterKit: 27573 35617
28 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 29
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany15 Stand-alone operation 15 Stand-alone operation
15 Stand-alone Betrieb 15 Stand-alone Betrieb
15.3 Introduction 15.3 Einführung 15.6 Description of the Main Window 15.6 Beschreibung des Hauptfensters
With the Drive Assistant control program, Dunkermo- Mit dem Steuerungsprogramm Drive Assistant bietet 15.6.1 Description of the General 15.6.1 Beschreibung der allgemeinen
toren provides a comprehensive software tool with Dunkermotoren ein umfangreiches Softwaretool, mit Parameter Groups - Main Window Parametergruppen - Hauptfenster
which it is possible to extensively configure the vari- dem es möglich ist verschiedene Typen von BG- und
ous types of BG and GR motors. Via a parameterising GR Motoren umfangreich zu konfigurieren. Über eine
interface, the software establishes a connection with Parametrierschnittstelle stellt die Software die Verbin-
the controller and the motor and programs it with the dung mit dem Regler und Motor her und programmiert
individual configuration. By means of prepared masks diesen mit der individuellen Konfiguration. Innerhalb
within the software, you can program various modes der Software kann über vorgefertigte Masken eine
individually with extensive parameter selection. individuelle Programmierung in verschiedenen Modi
mit umfangreicher Parameterauswahl vorgenommen
werden.
15.4 System Requirements 15.4 Systemvoraussetzungen
Operating system: Windows 2000, Windows XP Betriebssystem: Windows 2000, Windows XP Home,
Home, Windows XP Pro, Windows Vista. The installa- Windows XP Pro, Windows Vista. Sie können die In-
tion files for the “Drive Assistant” can either be loaded stallations-Dateien für den „Drive Assistant“ entweder
from the CD-ROM provided or downloaded from the von der mitgelieferten CD-ROM oder von der Dunker- The following parameter groups are common to all modes: Allen Modi gemeinsam sind folgende Parametergruppen:
Dunkermotoren homepage. motoren Homepage herunterladen.
Group Field „Projects“ Gruppenfeld „Projects“
15.5 Installation of the Software Drive 15.5 Installation der Software Drive In the „Project“ group field, the configurablemo modis Im Gruppenfeld „Projects“ werden die konfigurier-
Assistant Assistant are shown. By double click on an elected modi, the baren Modis angezeigt. Durch Doppelklicken auf
elected project submission appears in a new window. ein gewähltes Modi, erscheint in neuem Fenster die
Administrator privileges are necessary for the instal- Zur Installation des Programms benötigen Sie Ad- gewählte Projektvorlage.
la-tion. The installation menu will start automatically min-Rechte. Nach dem Einlegen der CD-Rom öffnet
when you insert the CD-ROM. Alternatively you can sich das Installationsmenü automatisch. Sollte sich
open the file install.htm to open the installation menu. das Menü nicht automatisch öffnen, so öffnen Sie im
The programm will guide you through the installati- Windows-Explorer die sich auf der CD-Rom befin-
on routine. Go ahead with the installation in case a dende Datei install.htm. Sie werden nun durch das
warning notice concerning the USB driver will pop up. Installationsmenü geführt. Klicken Sie auf „Installation
After successful installation the Drive Assistant can be fortsetzen“, falls während der Installation ein Warnhin-
startet by the desktop link. weis bezüglich dem USB-Controller erscheint. Nach
erfolgreicher Installation kann der Drive Assistant über
die Desktop-Verknüpfung geöffnet werden.
15.6.2 Description of the Menu Bar 15.6.2 Beschreibung der Menüleiste
- Main Window - Hauptfenster
„Program“ Menu „Program“-Menü
With „Options“ the user can change the language of Mit „Options“ kann die Sprache der Hilfetexte geän-
the help text. With „Exit“ the user leaves the program. dert werden. Mit „Exit“ verlässt der Anwender das
Programm.
30 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 31
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany15 Stand-alone operation 15 Stand-alone operation
15 Stand-alone Betrieb 15 Stand-alone Betrieb
„Projects“ Menu „Projects“-Menü 15.7.1 Description of the General Paramter 15.7.1 Beschreibung der allgemeinen
Groups - Project Window Parametergruppen - Projektfenster
In the „Projects“ menu, the user can copy a current Im „Projects“-Menü kann der Anwender ein aktuelles
project („Copy project“) or delete it („Delete project“). Projekt kopieren („Copy project“) oder löschen „Connected“ Group Field Gruppenfeld „Connected“
In addition the possibility exists to import an project („Delete project“). Zusätzlich besteht die Möglichkeit,
(„Import project“). ein Projekt zu importieren („Import project“).
In the “Connected” group field, information can be Im Gruppenfeld „Connected“ finden sie Informationen
found about the hardware and software versions. über die Hardware- und Softwareversionen. Zusätz-
Additionally the attached motor is termed. lich wird der angeschlossene Motor benannt.
„View“ Menu „View“-Menü As long as the controller is not connected to the PC Solange der Regler nicht über das Interfacekabel zum
via the interface cable and the motor is not connected PC verbunden ist und der Motor nicht mit dem Regler
In the „View“ menu, the user has the possibility of Im „View“-Menü hat der Anwender die Möglichkeit, die with the controller and not with the supply voltage, no und nicht mit der Versorgungsspannung angeschlos-
displaying or hidint the status bar („Status Bar“). Anzeige der Statusleiste („Status Bar“) wahlweise ein- version data are shown. sen ist, erscheinen keine Versionsangaben.
bzw. ausblenden zu lassen.
„Connection“ Group Field Gruppenfeld „Connection“
„Help“ Menu „Help“-Menü The “MOTOR STOP” button is a safety function that Die Schaltfläche „MOTOR STOP“ ist eine Sicherheits-
serves to bring the connected motor to an immediate funktion, die dazu dient, bei angeschlossenem Motor
In the “Help” menu, the user has the possibility of regi- Im „Help“-Menü hat der Anwender die Möglichkeit, standstill. einen sofortigen Stillstand herbeizuführen.
stering his version of the Drive Assistant. seine Version des Drive Assistant zu registrieren.
In addition, the possibility exists for displaying with Zusätzlich besteht die Möglichkeit, sich über „About…“
“About…” the detailed version data. die ausführliche Versionsdaten anzeigen zu lassen.
„Selected“ Group Field Gruppenfeld „Selected“
In the “Selected” group field, the outputs are the cur- Im Gruppenfeld „Selected“ wird sowohl die aktuelle
rent project number and the setting designation. Modinummer sowie die spezifische Einstellungsbe-
The default settings cannot be loadod on the control- zeichnung ausgegeben. Die voreingestellten Default-
15.7 Description of the Project Window 15.7 Beschreibung des Projektfensters ler. To save proper adjusted settings, you go in the werte können nicht auf den Regler geladen werden.
menu bar of file --> „Safe as...“. Here the modi can be Um selbst erstellte Einstellungen abzuspeichern
designated and it is directly loaded. gehen Sie in der Menüleiste auf File --> „Save as...“.
Hier kann dar Modi benannt und direkt geladen
werden.
Additionally the attached motor can be selected here. Zusätzlich kann hier der angeschlossene Motor aus-
gewählt werden.
With “Load to Motor”, the currently selected modi can Mit „Load to Motor“ kann der aktuell ausgewählte
be transmitted to the controller. Modi auf den Regler übertragen werden.
After transmission, the voltage must be briefly discon- Nach der Übertragung muss die Spannung kurz vom
nected from the controller. Only then is the controller Regler getrennt werden. Erst dann ist der Regler
ready for operation. betriebsbereit.
32 Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de Instruction Manual/Betriebsanleitung BGE 3515 / 6010, Version: 1.1 en_de 33
© 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; Germany © 2009 Alcatel-Lucent; Dunkermotoren; D-79848 Bonndorf; GermanySie können auch lesen


